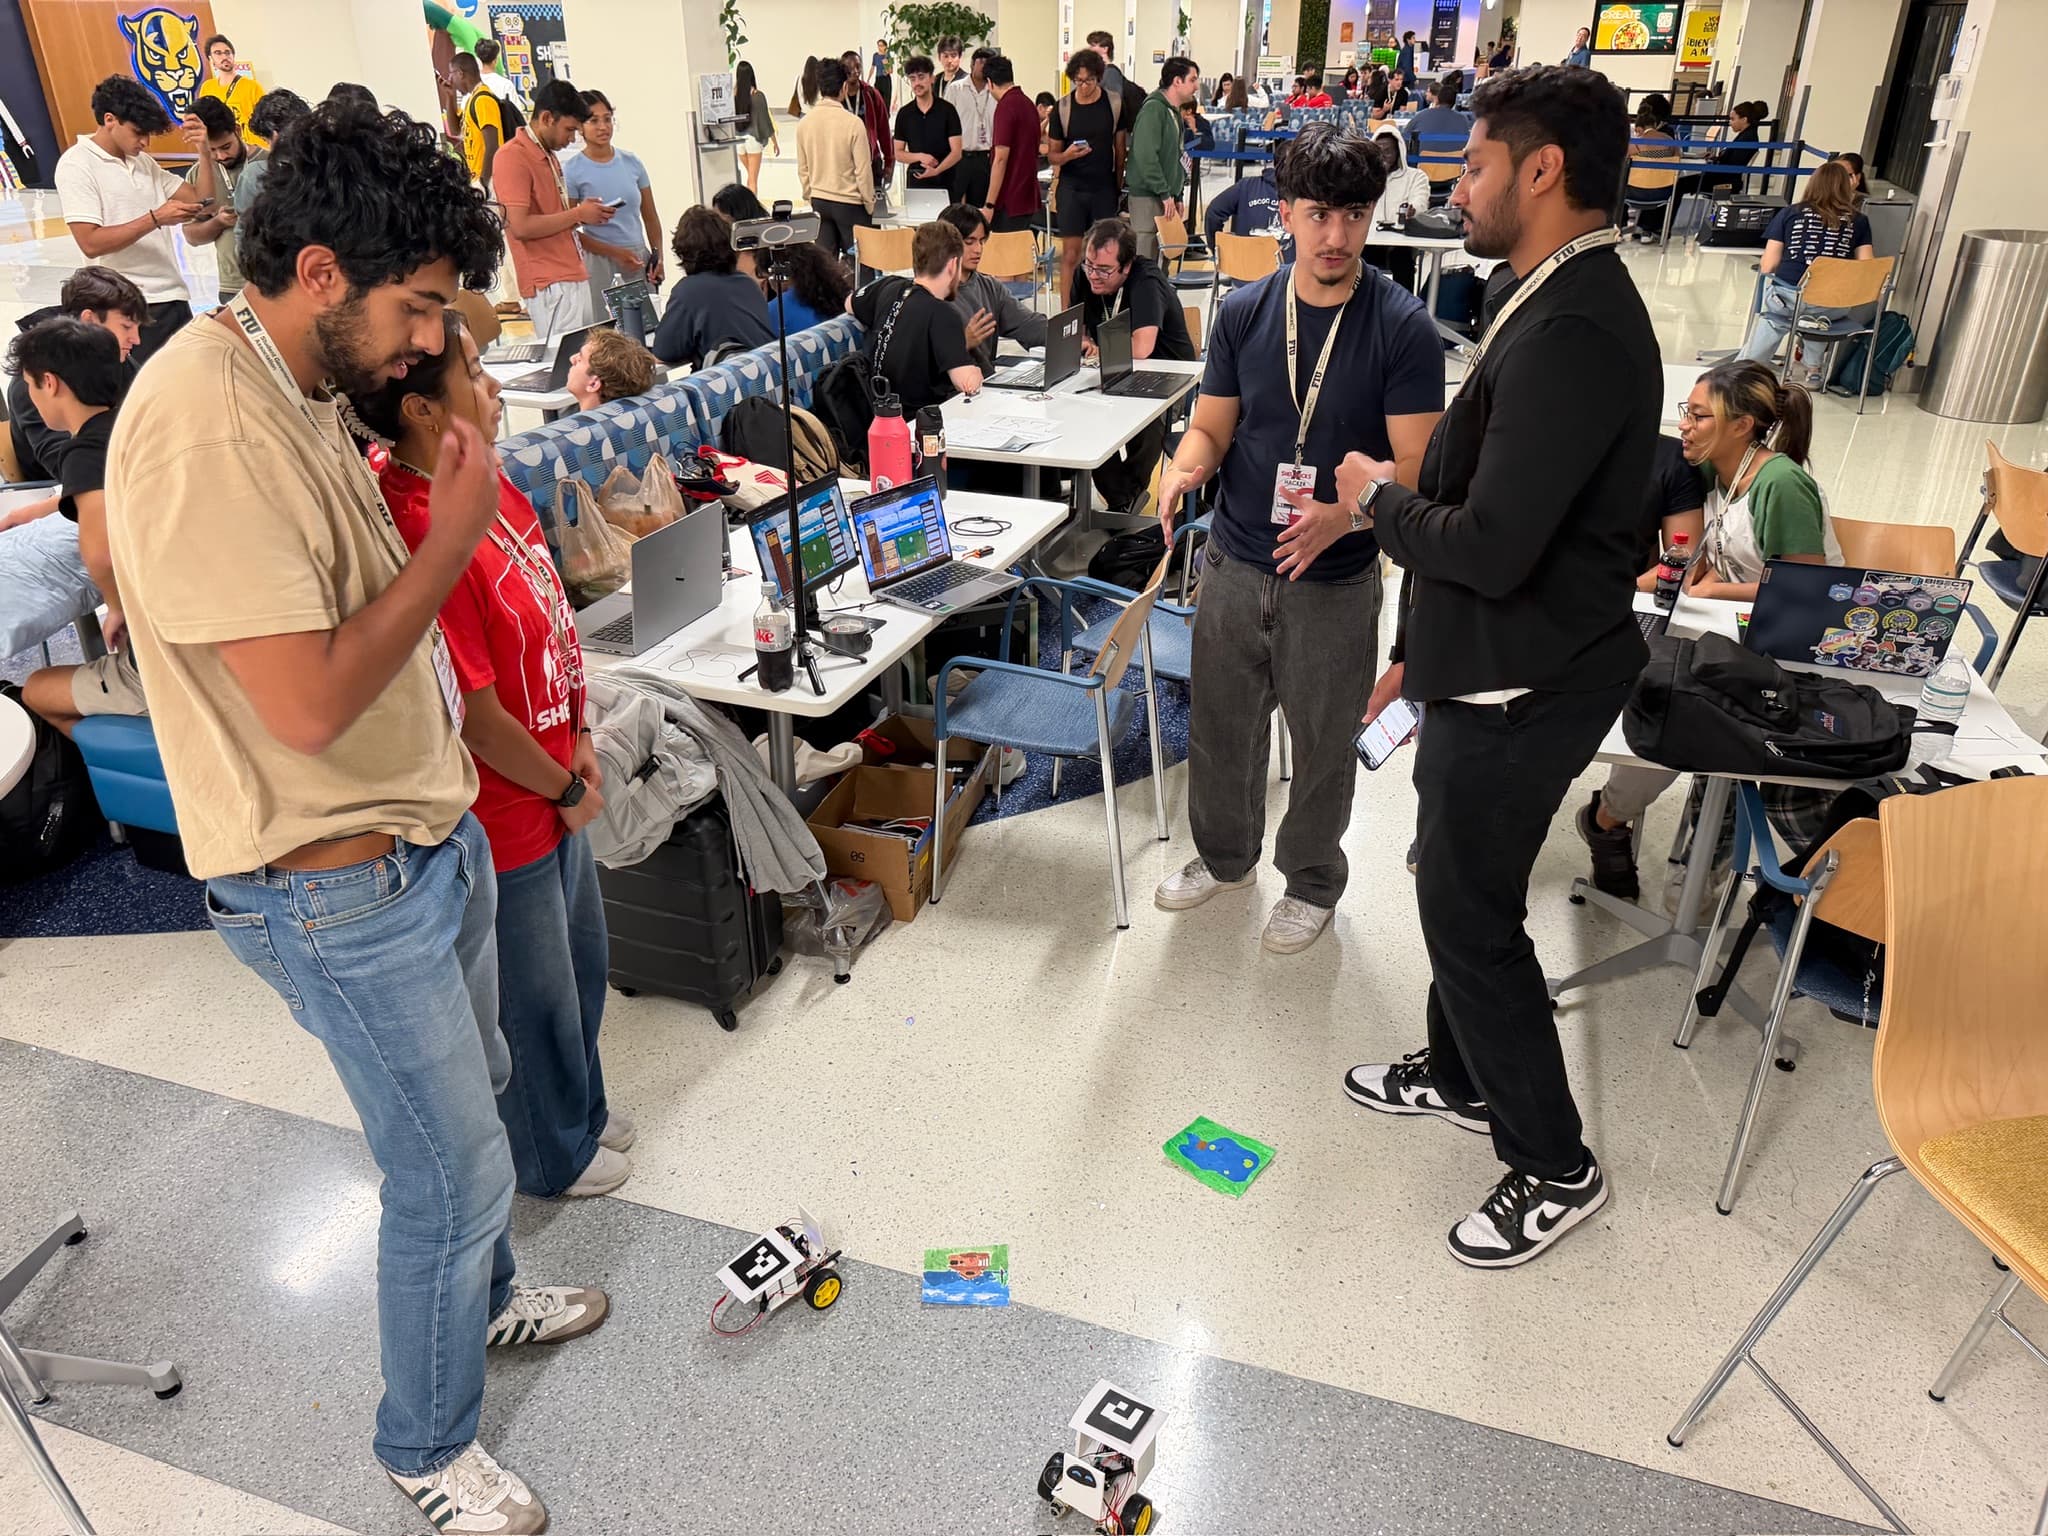
ShellHacks 2026 / Robotics
Lovebugs.
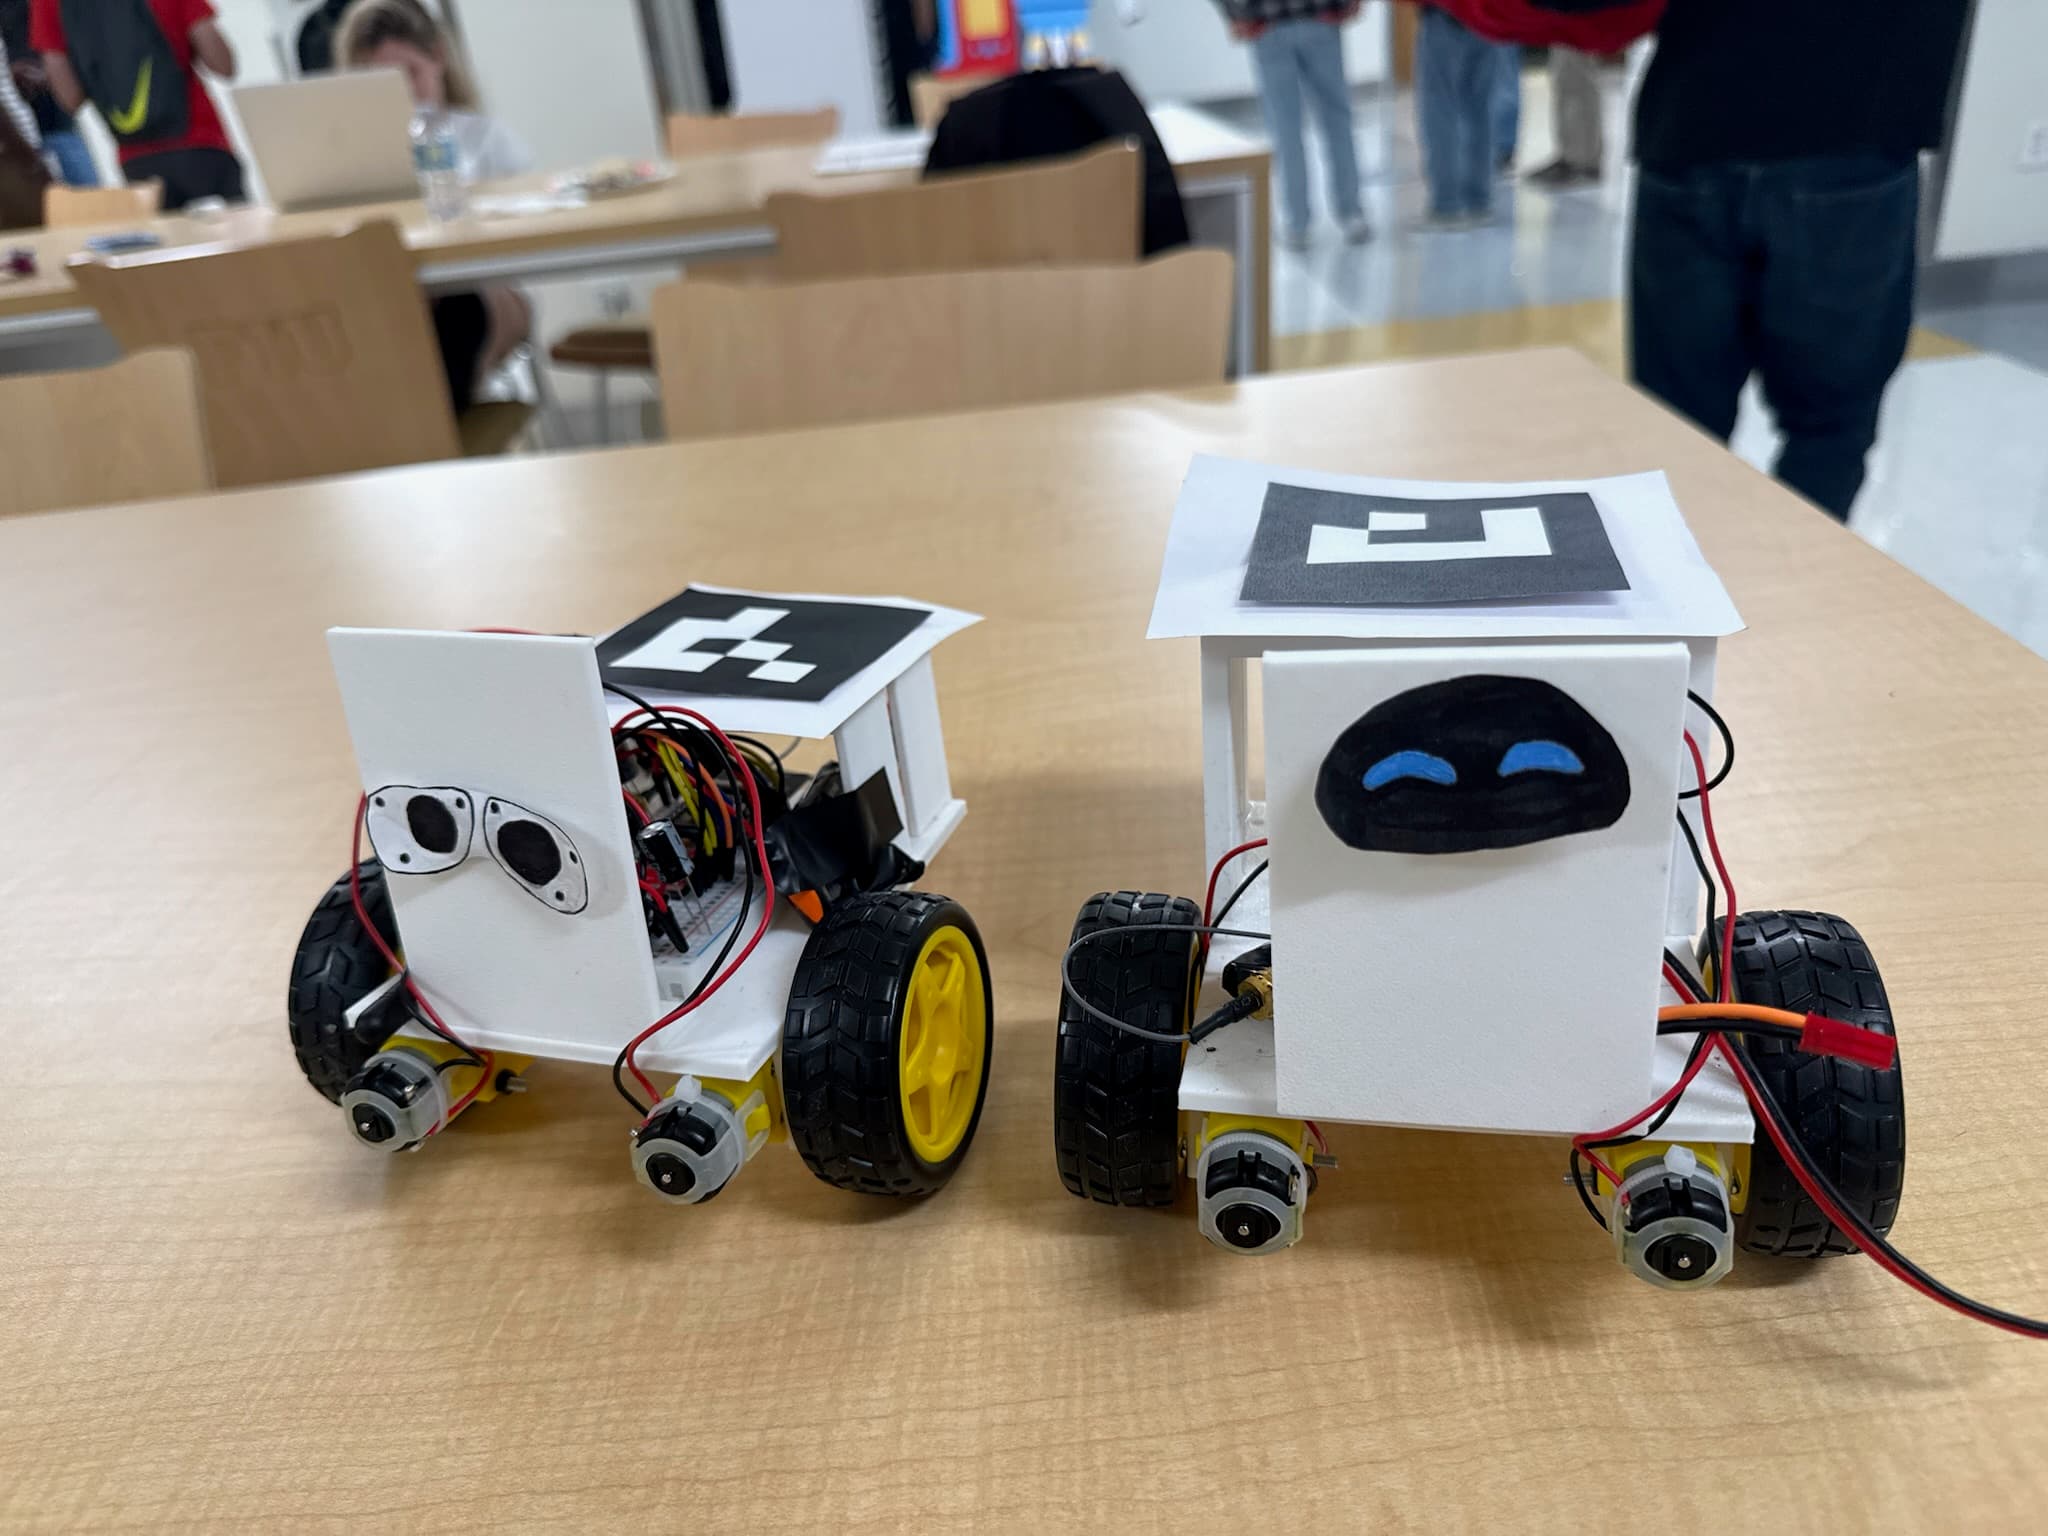
Small robots. One coordinated fleet.
From overhead vision to physical movement.
The build
A multi-agent robotics system
A collaborative build connecting AI coordination, a shared simulation, and two custom physical robots.
My contribution
I focused on AI agent orchestration, embedded firmware, and integrating high-level agent decisions with robot control.
How it fits together
Highlighted lines show related flows · Dashed line: camera observation
Simulation
AI agents
Agents reason about tasks, communicate, manage resources, and coordinate within a shared Stardew Valley-inspired environment.
- Agent coordination ↔ shared world state
My focus: AI agent orchestration.
Gemini / ADK → FastAPI → navigation & control → ESP32 firmware → motors
OpenCV / ArUco → position feedback · React / WebSockets → shared environment & agent activity
Simulation ≠ hardware demo. Multi-agent coordination worked in the shared simulation. The physical integration connected vision, navigation, and embedded control; not every simulated action was demonstrated on the robots.
From the hackathon floor